Niclas Zeller

Niclas Zeller

Professor of Signal Processing and Mobile Robotics

Karlsruhe University of Applied Sciences

About Me

In 2013, I received Master’s degrees in Electrical Engineering from Karlsruhe University of Applied Sciences and in Electrical and Computer Engineering from Toronto Metropolitan University (TMU) (formerly Ryerson). Afterwards, I was working towards my doctoral degree at Karlsruhe University of Applied Sciences in collaboration with the Technical University of Munich (TUM). In 2018, I defended my thesis with the title “Direct Plenoptic Odometry – Robust Tracking and Mapping with a Light Field Camera”. Between 2018 and 2019, I was working at Visteon in Karlsruhe. In 2019, I joined the startup Artisense in Munich co-founded by Prof. Daniel Cremers (TUM). Since September 2021, I am a professor at the Faculty of Electrical Engineering and Information Technology at Karlsruhe University of Applied Sciences.

Interests

  • 3D Computer Vision
  • Autonomous Driving
  • Mobile Robotics
  • Digital Signal Processing

News

[09/2026] Aymeric Fleith’s paper PRISM-VO on light field camera based SLAM has been accepted as oral presentation at ECCV 2026 in Malmo.

[09/2026] We are organizing the 2nd workshop on Visual Localization and Mapping (ViLMa) at ECCV in Malmo.

[06/2026] I’m among the outstanding reviewers at CVPR 2026.

[03/2026] Xuqin Wangs’s work GeodesicNVS on geodesic flow matching for novel view synthesis has been accepted at CVPR 2026 in Denver.

[10/2025] We are organizing a workshop on Multi-modal Localization and Mapping (MuLMa) at ICCV in Honolulu. The workshop will take place on October 19, 2025.

Research
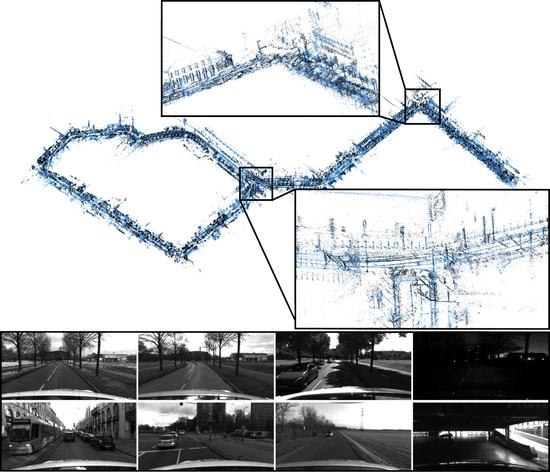
Map-based Localization

Map-based Localization

Localization within a pre-build map based on camera images
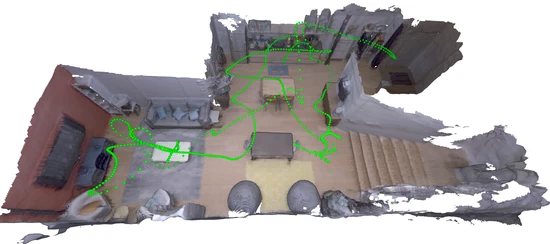
Dense 3D Reconstruction

Dense 3D Reconstruction

Dense 3D reconstruction and scene understanding from cameras
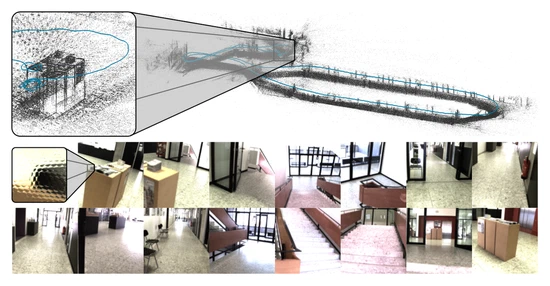
Light Field Processing

Light Field Processing

Depth estimation, localization and 3D mapping using 4D light field cameras

Selected Publications

PRISM-VO: Scale-Aware Visual Odometry Using Photometric Plenoptic Bundle Adjustment
Aymeric Fleith, Julian Zirbel, Daniel Cremers, Niclas Zeller
European Conference on Computer Vision (ECCV); 2026
Oral Presentation
Single-Frame Radar Object Detection and Segmentation Using a CNN–Swin Hybrid Architecture
Iqbal Banwait, Niclas Zeller, Javad Alirezaie
European Signal Processing Conference (EUSIPCO); 2026
MambaPanoptic: A Vision Mamba-based Structured State Space Framework for Panoptic Segmentation
Qing Cheng*, Damiano Bertolini*, Wei Zhang, Dong Wang, Niclas Zeller, Daniel Cremers
ISPRS Annals of the Photogrammetry, Remote Sensing and Spatial Information Sciences (Proc. XXV ISPRS Congress); 2026
* Equal contribution
GeodesicNVS: Probability Density Geodesic Flow Matching for Novel View Synthesis
Xuqin Wang, Tao Wu, Yanfeng Zhang, Lu Liu, Mingwei Sun, Yongliang Wang, Niclas Zeller, Daniel Cremers
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR); 2026
A Digital RFSoC SDR Architecture for GPS-like High-Accuracy Time-of-Flight Measurements
Tristan Itschner, Simon Huh, Niclas Zeller
IEEE Radar Conference (RadarConf); 2026
HI-SLAM2: Geometry-Aware Gaussian SLAM for Fast Monocular Scene Reconstruction
Wei Zhang, Qing Cheng, David Skuddis, Niclas Zeller, Daniel Cremers, Norbert Haala
IEEE Transactions on Robotics; 2025
LADB: Latent Aligned Diffusion Bridges for Semi-Supervised Domain Translation
Xuqin Wang, Tao Wu, Yanfeng Zhang, Lu Liu, Dong Wang, Mingwei Sun, Yongliang Wang, Niclas Zeller, Daniel Cremers
DAGM German Conference on Pattern Recognition (GCPR); 2025
VoxNeRF: Bridging Voxel Representation and Neural Radiance Fields for Enhanced Indoor View Synthesis
Sen Wang, Qing Cheng, Stefano Gasperini, Wei Zhang, Shun-Cheng Wu, Niclas Zeller, Daniel Cremers, Nassir Navab
IEEE Robotics and Automation Letters; 2025

Experience

Professor
09/2021 – Present Karlsruhe
Lecturer
09/2020 – 03/2021 Munich
Senior Computer Vision and AI Engineer
05/2019 – 08/2021 Munich
ADAS Perception Engineer
05/2018 – 04/2019 Karlsruhe
Lecturer
05/2018 – 04/2019 Karlsruhe
Dr.-Ing. in Photogrammetry / Computer Vision
04/2013 – 10/2018 Munich / Karlsruhe
M.Eng. in Electrical and Computer Engineering
09/2012 – 03/2013 Toronto
M.Eng. in Electrical Engineering
04/2011 – 03/2013 Karlsruhe
B.Eng. in Communications Engineering and Information Technology
09/2007 – 03/2011 Karlsruhe

Contact